Wenqi Wang
SYD --:--:-- AEST
Lab ↗

Wenqi Wang / Physical-AI engineer · FounderWenqi Wang / Physical AI 工程师 · 创业者

Hi, I’m Wenqi.
I build with AI.
你好,我是 Wenqi。
我用 AI 创造。

I explore AI-native ways of learning and building, with a focus on how Physical AI connects sensing, compute and action. From agents to embedded systems, I test ideas on real hardware and log every experiment. 我探索 AI-Native 的学习与创造方式,关注 Physical AI 如何连接感知、计算与行动。从智能体到嵌入式系统,在真实硬件上验证想法,记录实验与成长。

AI-NativePhysical AIEmbedded systems

Sydney, AU · 33.87°S 151.21°E · building Aurai Sensing澳大利亚悉尼 · 33.87°S 151.21°E · 正在打造 Aurai Sensing

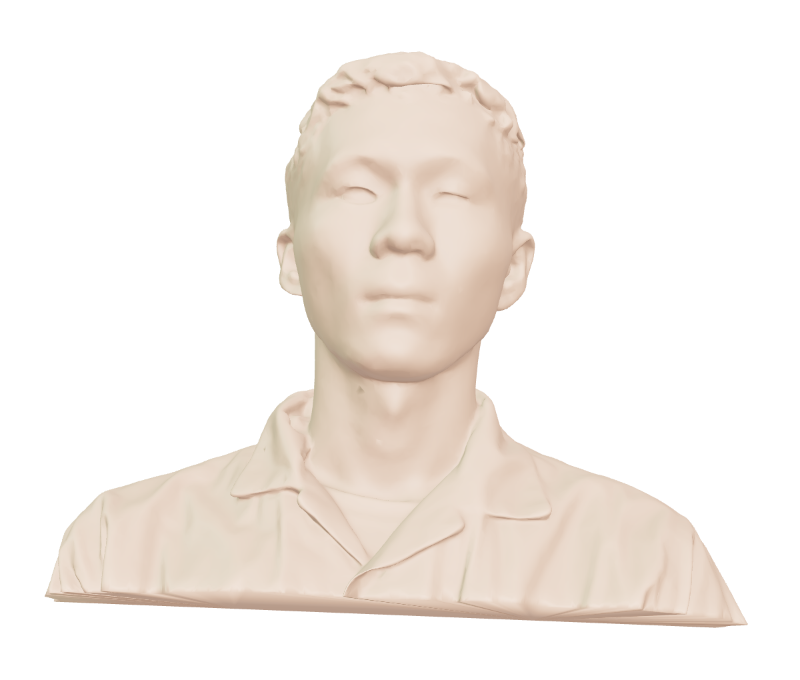
3D-scanned bust of Wenqi

Digital self · 3D scan v5

A little curiosity. A lot of possibility. Keep exploring继续探索 Ideas → Experiments → Reality
  • STM32
  • CC1310 Sub-1GHz
  • TI 15.4-Stack
  • ESP32
  • MQTT
  • TimescaleDB
  • ROS
  • Jetson Nano
  • OpenMV
  • YOLOv5
  • FPGA
  • TinyML
  • MSPM0 NPU
  • LLaMA3 + RAG
  • vLLM
  • DGX Spark
  • Codex
  • Claude Code
  • n8n
  • Activepieces
  • SolidWorks
  • Altium
  • Three.js

02 / Profile

Measurement first.
Intelligence on top.
先把世界测准,
再让它变聪明。

I’m an instrument engineer turned Physical-AI builder. I trained in Measurement & Control Technology and Instruments at China Jiliang University, the discipline of turning the physical world into data you can trust. I’ve been designing and soldering my own boards since my first STM32 minimum system in 2021.

我是一名从测控仪器走向 Physical AI 的工程师。本科就读于中国计量大学测控技术与仪器专业(光电检测方向),这门学科的核心是把物理世界变成可信的数据。从 2021 年自己设计并焊接第一块 STM32 最小系统板开始,我一直在真实硬件上动手。

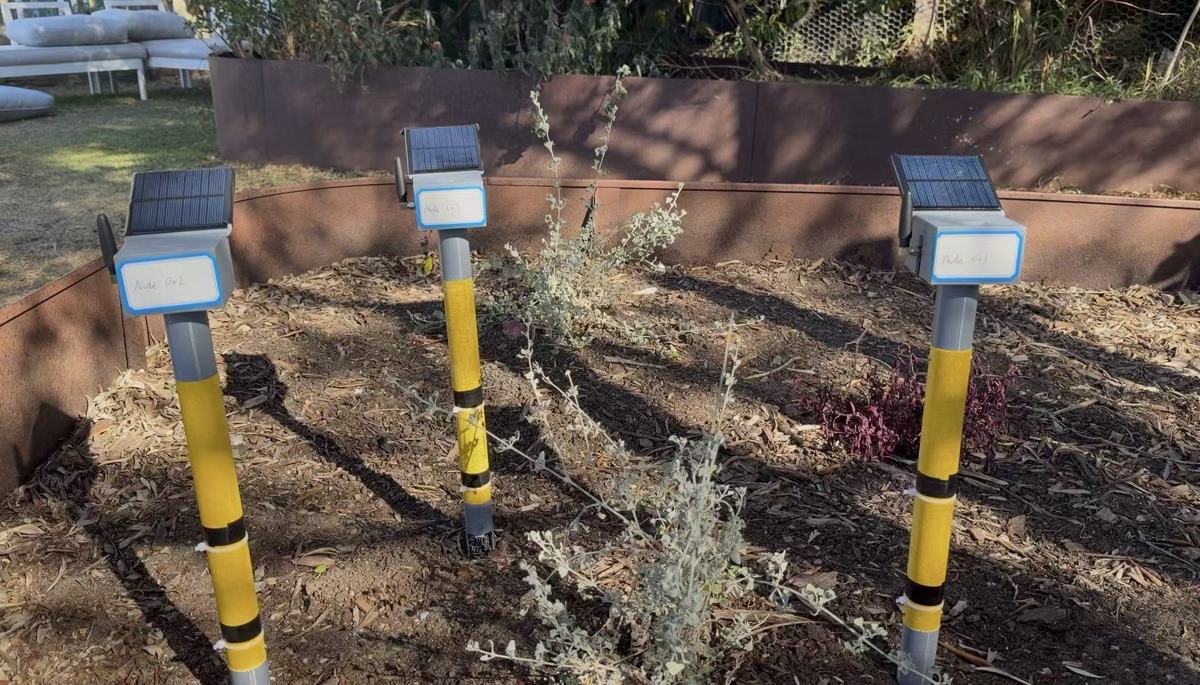
Since then I’ve built picking robots, smart-car vision, FPGA-accelerated CNNs, a pipeline leak-tracing robot and Sub-1GHz sensor networks for agriculture, and documented all of it in my Lab. Now in Sydney, I founded Aurai Sensing to bring that stack to horticulture: self-powered field nodes that read soil and canopy and decide on-device.

此后做过采摘机器人、智能车视觉、FPGA 加速 CNN、管道泄漏溯源机器人,以及面向农业的 Sub-1GHz 无线传感网络,过程都完整记录在我的 Lab 里。现在我在悉尼创立了 Aurai Sensing,把这套技术栈带进园艺农业:自供能田间节点持续读取土壤与冠层数据,并在端侧做出决策。

My workflow is agent-native. Coding agents drive toolchains, firmware, CAD and data pipelines, while I stay close to what the hardware is actually doing: the oscilloscope, the power trace, the field.

我的工作方式是 AI-Native 的:编码 Agent 驱动工具链、固件、CAD 与数据管线,而我专注于硬件的真实反馈——示波器、功耗曲线与田间现场。

Embedded C/C++PythonPCB designSub-GHz RFComputer visionEdge AIIoT platformsAI agents
wenqi@lab:~$ whoami --verbose
name    Wenqi Wang
role    Physical-AI engineer · Founder, Aurai Sensing
base    Sydney, Australia
trained Measurement & Control Tech · Instruments
loop    sense → infer on-device → act
silicon STM32 · CC1310 · ESP32 · MSPM0 · Jetson
agents  Codex · Claude Code · n8n · Activepieces
status  ● building first field pilot, Sep 2026
wenqi@lab:~$ 
40+
public build logs and write-ups in the Lab篇公开的 Lab 实验记录与项目复盘
10+
competition awards in embedded, optoelectronic and mechanical design项嵌入式、光电与机械设计等竞赛奖项
16
projects featured below, from 2021 to now个精选项目,2021 年至今
2026
founded Aurai Sensing Pty Ltd创立 Aurai Sensing Pty Ltd

03 / Journey

From a soldering iron
to a company.
从一把烙铁,
到一家公司。

  1. 2021 — 25

    China Jiliang University

    B.Eng., Measurement & Control Technology and Instruments测控技术与仪器 本科(光电检测方向)

    Optoelectronic-detection stream of a Washington Accord–accredited programme, ranked 15 of 254 nationally (ARWU 2024). First project: an STM32F103 minimum-system board I designed in Altium and soldered myself.

    《华盛顿协议》互认体系认证专业,2024 软科专业排名 15/254。第一个项目:用 Altium Designer 自主设计并焊接调试 STM32F103 最小系统板。

  2. 2022 — 23

    Competitions学科竞赛

    Ten-plus competition awards十余项竞赛奖项

    2nd prize, National Embedded Chip & System Design Competition (East, 2023). 3rd prize, National Optoelectronic Design Competition (East, 2023). Provincial prizes in electronic design (TI Cup), mechanical design and physics innovation, and 1st prize in the university’s “Internet+” innovation contest.

    2023 全国大学生嵌入式芯片与系统设计竞赛东部赛区二等奖;2023 全国大学生光电设计竞赛东部赛区三等奖;TI 杯省级电子设计竞赛、浙江省大学生机械设计竞赛、物理实验与科技创新竞赛等省级奖项;校级“互联网+”创新创业大赛一等奖。

  3. 2023 — 24

    National Innovation Training Program国家级大学生创新训练计划

    Navel-orange picking robot基于机器视觉和柔性末端的脐橙采摘机器人

    OpenMV and K210 vision guiding an STM32F407-driven arm with a soft gripper: line following, PID tracking and a full SolidWorks assembly. Concluded 2024.

    OpenMV 与 K210 视觉引导 STM32F407 控制的机械臂和柔性夹爪,实现巡线、PID 跟踪与目标抓取;SolidWorks 完成整机装配,2024 年结题。

  4. 2024

    Industry placements企业实践

    SCANTECH & ACCRETECH (Tokyo Seimitsu)思看科技 · 东京精密 暑期实践

    Summer practice at a 3D-scanning company and a precision-metrology company, seeing measurement science at production scale. The same year: a registered software copyright for an image-processing microscope coal-dust detector.

    在 3D 扫描与精密测量企业的暑期实践,让测控专业方向变得具体;同年获得《基于图像处理的显微镜下煤粉检测软件》计算机软件著作权。

  5. 2025

    Graduation projects毕业设计

    Sub-1GHz sensor nodes & a microgreens AIoT systemSub-1GHz 传感节点与微型蔬菜农业物联网

    Designed and hand-soldered CC1310 RF boards with a localised BOM, and built a Raspberry Pi 4B + ESP32 system that combines environment sensing, image recognition and remote control.

    自主设计并焊接 CC1310 射频板(元器件国产化替代),并基于树莓派 4B 与 ESP32 搭建集环境监测、图像识别与远程控制于一体的系统。

  6. 2025 →

    The University of Sydney

    Postgraduate engineering in Sydney悉尼大学 · 工程研究生

    Moved to Sydney for postgraduate engineering: communication networks, technology management, and a capstone that became a company’s first deployment.

    来到悉尼攻读工程研究生:通信网络、技术管理,以及一个最终成为公司首个落地部署的 Capstone 项目。

  7. Apr 2026

    Aurai Sensing Pty Ltd

    Founded Aurai Sensing创立 Aurai Sensing

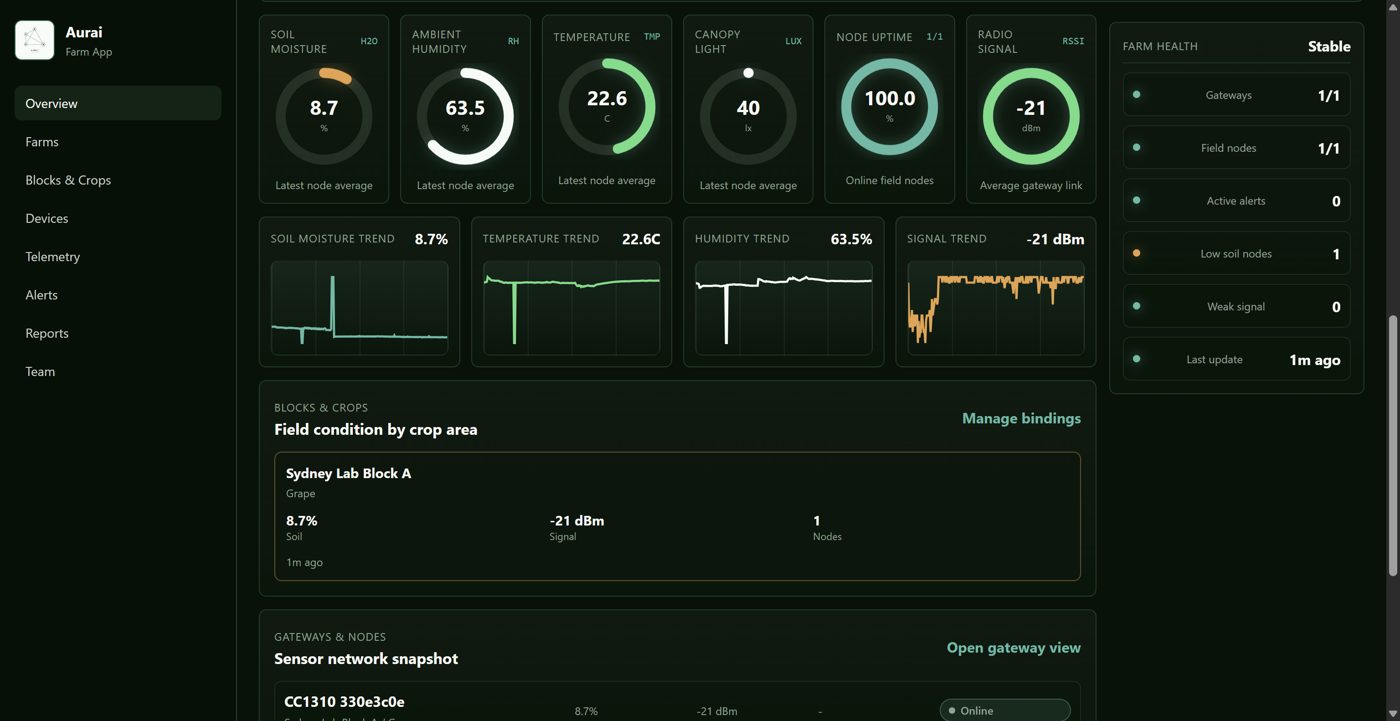
    IoT- and AI-driven precision irrigation for high-value horticulture: solar field nodes, a 915 MHz self-healing mesh, Field OS, and an agent growers can ask questions.

    面向高价值园艺的 IoT + AI 精准灌溉:太阳能田间节点、915 MHz 自愈 Mesh 网络、Field OS,以及种植者可以直接提问的农业 Agent。

  8. Sep 2026

    University of Sydney Capstone悉尼大学 Capstone 项目

    First field pilot首个田间试点部署

    A full node mesh running continuously across a real horticultural property.

    完整的节点 Mesh 在真实园艺农场中持续运行。

04 / Selected work

Things I’ve built,
on real hardware.
在真实硬件上,
做出来的东西。

Sixteen projects from 2021 to now. Each “Build log” link opens the full write-up in my Lab (in Chinese). 2021 年至今的 16 个项目,点击「实验记录」可在 Lab 中阅读完整过程。

012026

Agent-designed product enclosuresAgent 驱动的产品外壳设计

Fed BOMs and module specs to a frontier model, iterated a modular housing in SolidWorks, then 3D-printed prototypes to check holes and fit.

把元器件清单与模块规格交给大模型,在 SolidWorks 中迭代模块化外壳,再 3D 打印打样验证孔位与结构。

SolidWorksLLM CAD3D printing
Build log实验记录
022026

Turning a smart speaker into an agent endpoint把智能音箱改造成 Agent 入口

At an n8n hackathon: opened the speaker, wired UART, and let an agent guide the firmware backup and SSH access, working toward voice → LLM → n8n automations.

n8n 黑客松:拆机、接 UART 串口,在 Agent 指导下完成固件备份与 SSH 登录,打通「语音入口 + LLM + n8n 自动化」。

UARTEmbedded Linuxn8n
Build log实验记录
032026

Keyword spotting on an MCU’s NPUMCU NPU 上的关键词识别

Pre-registered architecture and training experiments for 12-class speech-command recognition on TI’s MSPM0G5187 hardware NPU, measured on the board itself.

在 TI MSPM0G5187 硬件 NPU 上做 12 类语音命令识别,按预先登记的方案进行结构搜索与训练,并在板上实测。

TinyMLMSPM0NPUKWS
Research in progress研究进行中
042026

The digital self数字分身

A 3D scan of me (30,104 vertices, 14 morph targets) rendered live in WebGL. The same bust fronts my Lab, and it’s the one at the top of this page.

我的三维扫描半身像——30,104 个顶点、14 个 Morph Target——在 WebGL 中实时渲染,也是本页顶部的那个模型。

Three.jsGLBWebGL
Back to the bust回到模型
052025

Sub-1GHz wireless sensor nodeCC1310 Sub-1GHz 无线传感节点

My own schematic and PCB for a CC1310 RF node with a localised BOM, hot-plate soldering of tiny packages, and radio link tests.

自主设计 CC1310 射频节点原理图与 PCB,元器件国产化替代,热板焊接微小封装并完成通信测试。

CC1310RF PCBLow power
Build log实验记录
062025

Microgreens AIoT system微型蔬菜农业物联网系统

A Raspberry Pi 4B + ESP32 platform that combines environment monitoring, image recognition and remote control for radish microgreens.

基于树莓派 4B 与 ESP32,集环境监测、图像识别与远程控制于一体的萝卜苗种植系统。

RPi 4BESP32CV
Build log实验记录
072023 — 24

Navel-orange picking robot脐橙采摘机器人

A national innovation project: OpenMV line following, K210 target detection, and an STM32F407 arm with a soft gripper.

国家级大创项目:OpenMV 巡线、K210 目标检测,STM32F407 控制机械臂与柔性夹爪完成抓取。

STM32F407OpenMVK210Soft gripper
Build log实验记录
082024

Automatic eggplant-harvesting line全自动茄子采收一体化系统

An integrated harvest system with a transport cart, a basket-swap mechanism, first-pass inspection and automatic box changing.

集运送小车、换篮机构、初级检测与自动换箱于一体的采收系统。

MechatronicsSolidWorksAutomation
Build log实验记录
092024

Steel surface-defect detection基于 YOLOv5 的钢材表面缺陷检测

A YOLOv5 pipeline that catches scratches, pits, cracks and rust on steel, replacing fatigue-prone manual inspection.

用 YOLOv5 检测钢材划痕、凹坑、裂纹与锈蚀,替代易疲劳的人工目检。

YOLOv5PyTorchIndustrial QA
Build log实验记录
102024

FPGA-accelerated CNN detection基于 FPGA 的 CNN 加速目标检测

A competition build covering model conversion, pruning and quantisation, IP-core calls, and ARM A9 + FPGA heterogeneous inference on a remote edge-AI platform.

竞赛项目:模型转换、剪枝量化、IP 核调用,在远程边缘 AI 平台上实现 ARM A9 + FPGA 异构推理。

FPGAQuantisationEdge AI
Build log实验记录
112023

Smart Car Competition: vision group智能汽车竞赛 · 智能视觉组

TSP route planning, a mecanum-wheel car and a robot arm, plus quantised classifiers squeezed onto an MCU camera (OpenART).

TSP 路径规划、麦克纳姆轮小车与机械臂,以及部署在 MCU 摄像头(OpenART)上的量化分类模型。

OpenARTTSPQuantised CNN
Build log实验记录
122023

Pipeline leak-tracing robot真空管道泄漏溯源机器人

Pneumatic inchworm propulsion with GPS, LiDAR and OpenMV vision, streaming to the cloud to build a digital twin of the pipe.

气囊链式推进,结合 GPS、激光雷达与 OpenMV 视觉,数据上云构建管道数字孪生。

STM32LiDARDigital twin
Build log实验记录
132024

Local LLM + RAG assistant本地大模型 + RAG 助手

LLaMA3 running in Docker on a laptop GPU, with retrieval over a personal knowledge base and live web-API calls.

在笔记本 GPU 上用 Docker 运行 LLaMA3,结合个人知识库检索(RAG)与实时 Web API 调用。

LLaMA3RAGDocker
Build log实验记录
142023

ROS robot on Jetson NanoJetson Nano ROS 麦克纳姆轮小车

STM32 low-level control under ROS on a Jetson Nano, with LiDAR mapping, a depth camera and obstacle avoidance.

STM32 下位机 + Jetson Nano 上的 ROS:激光雷达建图、深度相机与自主避障。

ROSJetsonLiDAR SLAM
Build log实验记录
05 / What’s next

Where I’m heading. 接下来,我要去的方向。

Three directions I keep investing in, each one built on something that already runs. 三条持续投入的方向,每一条都建立在已经跑起来的系统之上。

VECTOR 01

Physical AI at the edge端侧 Physical AI

Closing the loop from sensing to on-device inference to action. TinyML on MCU NPUs today, embodied systems tomorrow.

打通「感知 → 端侧推理 → 行动」的闭环:今天是 MCU NPU 上的 TinyML,明天是具身智能系统。

Grounded in已有基础 → MSPM0G5187 NPU keyword spotting

VECTOR 02

Agent-operable instrumentsAgent 可操作的智能仪器

The next instrument isn’t just a smarter sensor. It’s one an agent can drive: scopes, power analysers and signal generators that measure, tune and re-test on their own.

未来的仪器不只是更聪明的传感器,而是能被 Agent 操作的系统:示波器、功耗分析仪与信号发生器自主完成测量、调参与复测。

Grounded in已有基础 → AIoT Core, built end to end with agents

VECTOR 03

Autonomous horticulture at scale规模化的自主园艺

Taking Aurai from its first pilot to a grower cohort and a commercial rollout, with hardware revision two, three-depth probes and the full Field OS.

让 Aurai 从首个试点走向种植者试点计划与商业化落地:第二代硬件、三深度探针与完整的 Field OS。

Grounded in已有基础 → first field pilot, Sep 2026

Now 2026
  • First field pilot
  • Agent-native AIoT platform
  • TinyML NPU research
  • 首个田间试点
  • Agent 原生 AIoT 平台
  • TinyML NPU 研究
Next 2026 — 27
  • Aurai pilot cohort
  • Field OS + grower agent
  • Edge models on field nodes
  • Aurai 种植者试点计划
  • Field OS 与农业 Agent
  • 田间节点上的端侧模型
Horizon 2027 →
  • Commercial rollout
  • Agent-driven test benches
  • Embodied Physical AI
  • 商业化落地
  • Agent 驱动的测试台
  • 具身 Physical AI

07 / Connect

Let’s build something real. 一起把想法变成现实。

Open to collaborations in Physical AI, AIoT and agent-native hardware, and to conversations with growers, researchers and fellow builders. 欢迎在 Physical AI、AIoT 与 Agent 驱动的硬件开发方向合作,也欢迎种植者、研究者和同行交流。

LinkedIn ↗ wenqiwang1314@gmail.com →
Based in所在地Sydney, Australia澳大利亚 · 悉尼
Focus关注Physical AI · AIoT · Agents
Currently当前Building Aurai Sensing打造 Aurai Sensing